Intelligence embedded in the world.
We are building thinking machines that can understand, reason, and learn from the world around them, then choose actions by predicting their likely outcomes.
Our work starts with a simple question: what should intelligence feel like in the physical world?
Our WAM-0.1 dataset contains 300,029 physical transitions for studying action and change. Explore the dataset .
01
world thinking machines #
Learning what can happen next.
Our models learn a useful representation of the world before they act. They use that representation to understand a scene, compare possible actions, and choose a next step with more context.
02
Understanding the world #
Predicting the outcome of an action
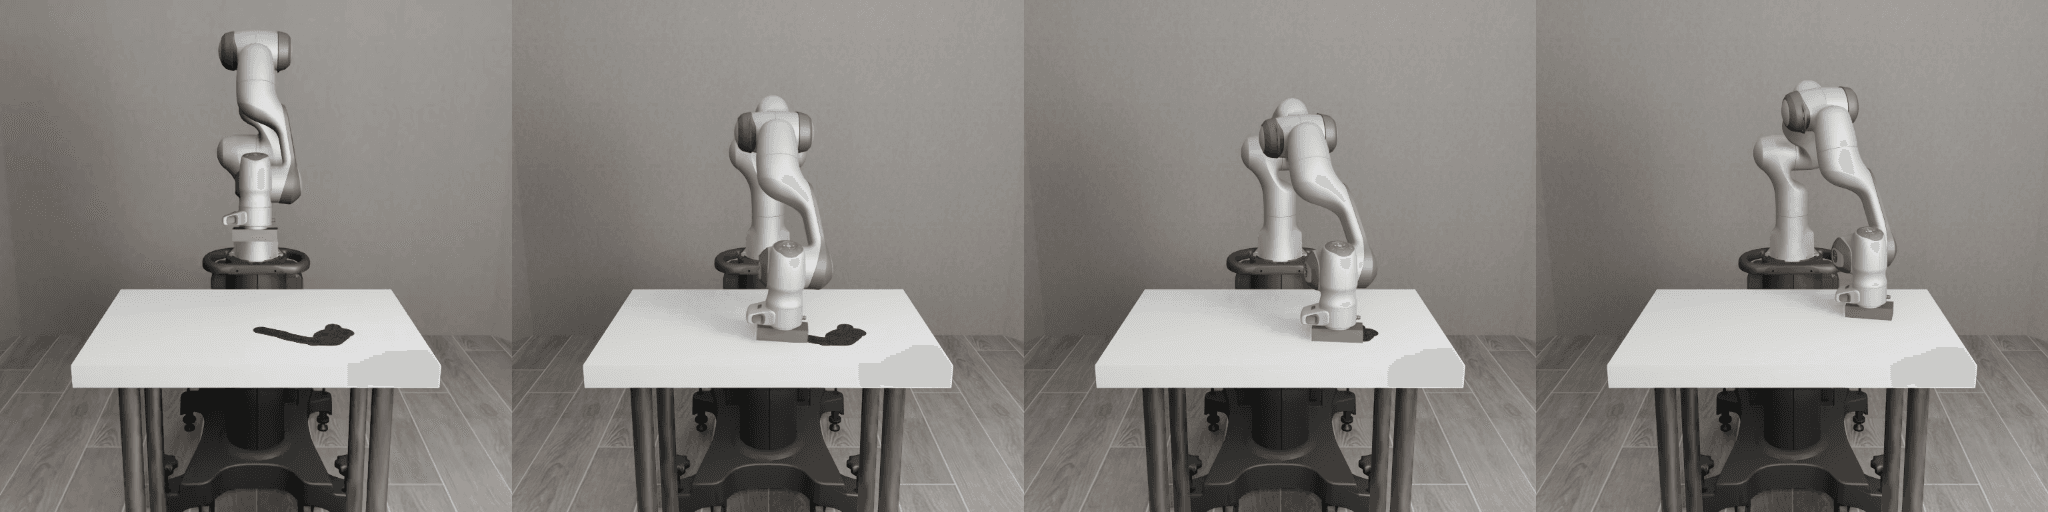
A robot needs to understand how its actions affect the space around it. We study how objects move and interact so a model can predict what may change before choosing its next action.
03
World Action Model #
A class of JEPA models for action and control.
The World Action Model ( WAM-1 ) will be our class of H-JEPA models that learns how actions change the world. Our first production model is planned at nearly one billion total parameters, giving it the capacity to predict outcomes and support longer-horizon robot tasks.
The model is still under development. Read our research on other topics here .
04
JEPA #
Predicting meaning instead of every pixel.
Joint Embedding Predictive Architectures let a model focus on the parts of an observation that matter for understanding and action. Our research builds on the predictive learning approach proposed by Yann LeCun.
read the JEPA paper05
H-JEPA #
Planning across longer horizons.
H-JEPA extends predictive learning across time. It gives a model a way to think about several possible futures, so a robot can organize a sequence of actions instead of reacting to one frame at a time.
read the H-JEPA paper06
Our goals #
Prediction, control, and recovery.
We want our systems to predict the result of an action before it happens, notice when a plan is failing, and recover without starting over. The larger goal is reliable behavior across tasks that take time and require several decisions.
07
Project Monarch #
Our earlier model.
Project Monarch was our earlier model and research direction. After internal assessment and testing, we shifted our focus to World Action Models for robotics and automation, where actions have observable effects that a model can learn to predict.
read about Project Monarch08
The timeline #
From simulation to capable machines.
We are starting with simulated environments where we can test prediction and control carefully. From there, we will study longer tasks, broader environments, and the steps needed to move these systems toward real robots.
FAQ